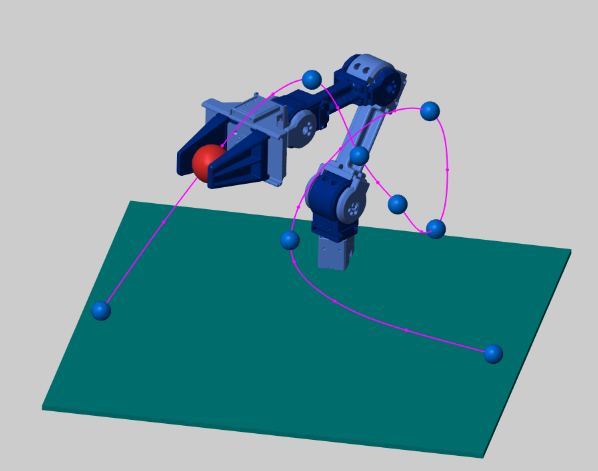
Designing Robot Manipulator Algorithms
MATLAB and Simulink files for modeling and simulation of ROBOTIS OpenManipulator
https://github.com/mathworks-robotics/designing-robot-manipulator-algorithms
Sie verfolgen jetzt diese Einreichung
- Aktualisierungen können Sie in Ihrem Feed verfolgter Inhalte sehen.
- Je nach Ihren Kommunikationseinstellungen können Sie auch E-Mails erhalten.
Zitieren als
MathWorks Student Competitions Team (2026). Designing Robot Manipulator Algorithms (https://github.com/mathworks-robotics/designing-robot-manipulator-algorithms), GitHub. Abgerufen .
Quellenangaben
Inspiriert von: Simscape Multibody Multiphysics Library, Simscape Multibody Contact Forces Library
Inspiriert: Mass Estimation for Manipulators using Sliding Mode Observer
Allgemeine Informationen
- Version (1,05 MB)
-
 Lizenz auf GitHub anzeigen
Kompatibilität der MATLAB-Version
- Kompatibel mit R2019b und späteren Versionen
Plattform-Kompatibilität
- Windows
- macOS
- Linux
| Version | Veröffentlicht | Versionshinweise | Action |
|---|---|---|---|
| 2.5.0 | Linked to GitHub. Updated to use new built-in contact forces in Simscape Multibody. Switched from Curve Fitting Toolbox splines to Robotics System Toolbox for cubic and trapezoidal velocity trajectories. |
||
| 2.4.0 | Bug fixes due to changes in external robot description repository. |
||
| 2.3.0 | Upgraded models to R2018b. Now using the built-in Inverse Kinematics block in Robotics System Toolbox. |
||
| 2.2.0 | Minor updates due to robot description file changes in the ROBOTIS GitHub repository. |
||
| 2.1.0 | Bug fixes to check and resolve external file dependencies. Added preloaded MATLAB object as a backup in case external files cannot be set up correctly. |
||
| 2.0.0 | Added torque control examples, using the new R2018a Robotics System Toolbox blocks. |
||
| 1.0.0 | Adding a script to check necessary dependencies for submission |

