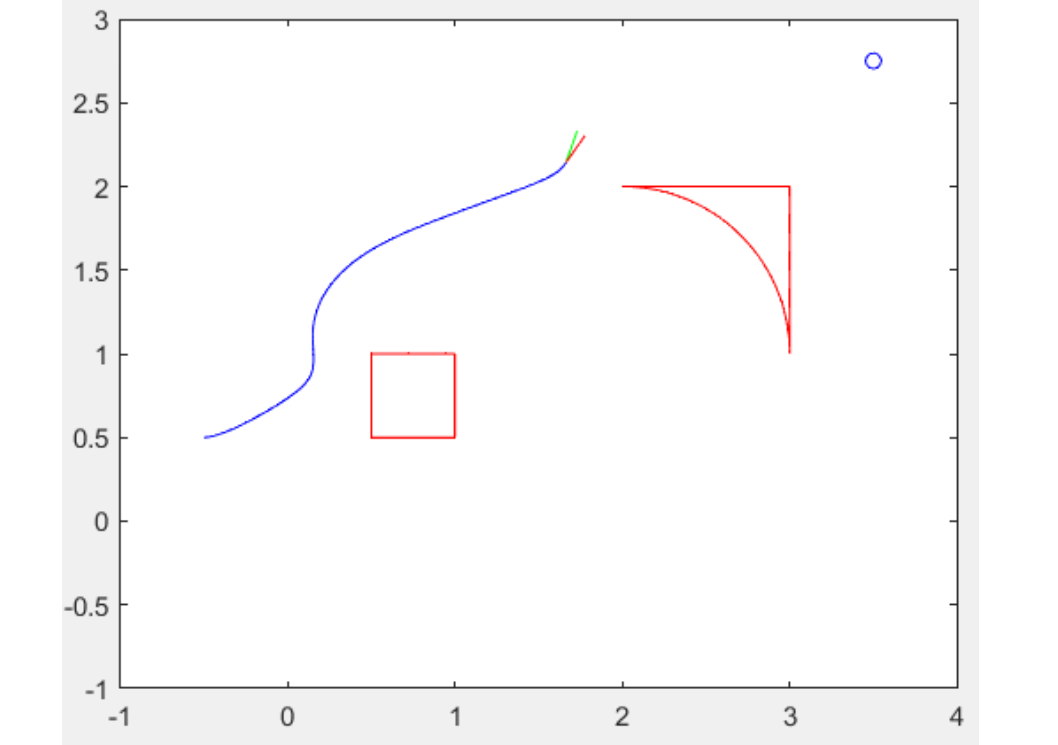
Artificial Potential Field path planning algorithm
A simple example of an Artificial Potential Field algorithm for autonomous operation in an unknown environment.

Sie verfolgen jetzt diese Einreichung
- Aktualisierungen können Sie in Ihrem Feed verfolgter Inhalte sehen.
- Je nach Ihren Kommunikationseinstellungen können Sie auch E-Mails erhalten.
Zitieren als
Szczepanski, Rafal, et al. “Energy Efficient Local Path Planning Algorithm Based on Predictive Artificial Potential Field.” IEEE Access, vol. 10, Institute of Electrical and Electronics Engineers (IEEE), 2022, pp. 39729–42, doi:10.1109/access.2022.3166632.
Allgemeine Informationen
- Version (2,19 KB)
Kompatibilität der MATLAB-Version
- Kompatibel mit allen Versionen
Plattform-Kompatibilität
- Windows
- macOS
- Linux
| Version | Veröffentlicht | Versionshinweise | Action |
|---|---|---|---|
| 1.0.0 |

