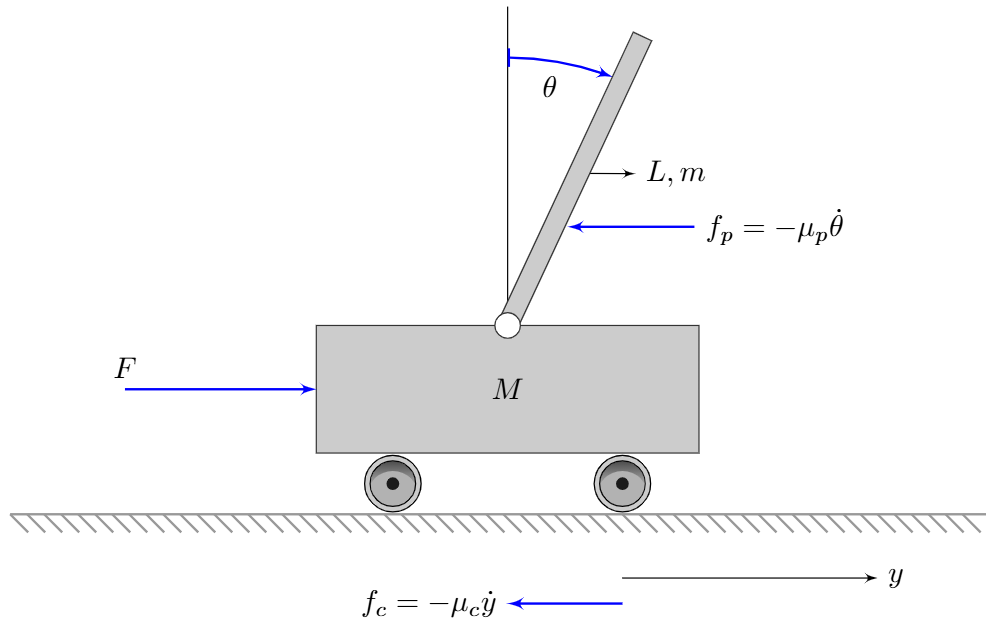
Design of Fuzzy and LQR Controller for Inverted Pendulum
LQR based on linear model and fuzzy controller designed directly with the nonlinear model.

Sie verfolgen jetzt diese Einreichung
- Aktualisierungen können Sie in Ihrem Feed verfolgter Inhalte sehen.
- Je nach Ihren Kommunikationseinstellungen können Sie auch E-Mails erhalten.
Zitieren als
Francisco J. Triveno Vargas (2026). Design of Fuzzy and LQR Controller for Inverted Pendulum (https://de.mathworks.com/matlabcentral/fileexchange/111990-design-of-fuzzy-and-lqr-controller-for-inverted-pendulum), MATLAB Central File Exchange. Abgerufen .
Allgemeine Informationen
- Version (17,2 KB)
Kompatibilität der MATLAB-Version
- Kompatibel mit R2023b
Plattform-Kompatibilität
- Windows
- macOS
- Linux
| Version | Veröffentlicht | Versionshinweise | Action |
|---|---|---|---|
| 4.0.0 | Change the Figure of the problem. |
||
| 3.0.0 | The LQR design was improved and updated. |
||
| 2.0.0 | Include the *.fis models |
||
| 1.0.0 |

