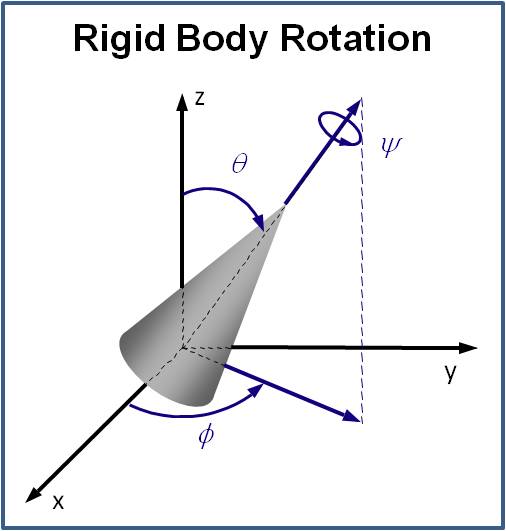
quaternion
quaternion class, vectorized, converts among rotation representations, numerical Euler propagation

Sie verfolgen jetzt diese Einreichung
- Aktualisierungen können Sie in Ihrem Feed verfolgter Inhalte sehen.
- Je nach Ihren Kommunikationseinstellungen können Sie auch E-Mails erhalten.
Zitieren als
Mark Tincknell (2026). quaternion (https://de.mathworks.com/matlabcentral/fileexchange/33341-quaternion), MATLAB Central File Exchange. Abgerufen .
Quellenangaben
Inspiriert von: Function to Convert between DCM, Euler angles, Quaternions, and Euler vectors
Allgemeine Informationen
- Version (20,4 KB)
Kompatibilität der MATLAB-Version
- Kompatibel mit allen Versionen
Plattform-Kompatibilität
- Windows
- macOS
- Linux
| Version | Veröffentlicht | Versionshinweise | Action |
|---|---|---|---|
| 1.8.0 | Fixed bug noted by Nathan Pust (thank you!) in rotationmatrix, updated RotationMatix, updated OmegaAxis, fixed bug in equiv. |
||
| 1.7.0 | Changes: revised error messages, corrected repmat syntax
|
||
| 1.6.0 | Added missing unitvector function for OmegaAxis method |
||
| 1.5.0 | change normalize, rand; fix isequal*, rotateutov; add dot, interp1, randRot |
||
| 1.3.0 | added quaternion.OmegaAxis to get angular velocity vectors from time series of quaternions |
||
| 1.2.0 | A few new methods and small bug fixes |
||
| 1.1.0 | fixed bugs, added some new methods |
||
| 1.0.0 |

