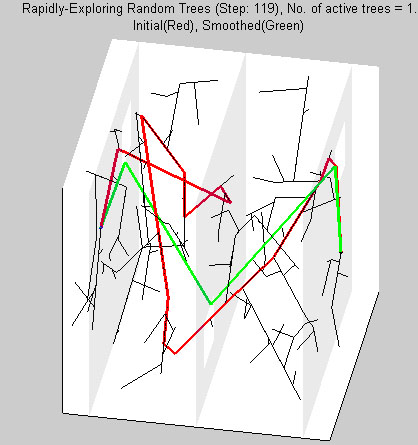
Multiple Rapidly-exploring Random Tree (RRT)
Multiple RRT implementation for mobile robot path planning or C-space manipulator motion planning

Sie verfolgen jetzt diese Einreichung
- Aktualisierungen können Sie in Ihrem Feed verfolgter Inhalte sehen.
- Je nach Ihren Kommunikationseinstellungen können Sie auch E-Mails erhalten.
Zitieren als
Gavin (2026). Multiple Rapidly-exploring Random Tree (RRT) (https://de.mathworks.com/matlabcentral/fileexchange/21443-multiple-rapidly-exploring-random-tree-rrt), MATLAB Central File Exchange. Abgerufen .
Allgemeine Informationen
- Version (14,7 KB)
Kompatibilität der MATLAB-Version
- Kompatibel mit allen Versionen
Plattform-Kompatibilität
- Windows
- macOS
- Linux
Communitys
Mehrere Dateien sind in der Power Electronics Control Community erhältlich
| Version | Veröffentlicht | Versionshinweise | Action |
|---|---|---|---|
| 1.4.0 | There was a bug in the Connect method that was sometimes creating incorrect connections. Thanks to David for the bug fix. |
||
| 1.3.0 | This is now in Matlab OO (i.e. it is a class).
|
||
| 1.0.0 |

