Quaternion Rotation
R2026bRotate vector by quaternion
Quaternion Rotation block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Aerospace Blockset /
Utilities /
Math Operations
Description
The Quaternion Rotation block calculates the resulting vector following the
passive rotation of initial vector vec by quaternion
q and returns a final vector, the rotated vector or vector of
rotated vectors. Aerospace Blockset™ uses quaternions that are defined using the scalar-first convention. This
block normalizes all quaternion inputs. For the equations used for the quaternion,
initial vector, and final vector, see Algorithms.
Examples
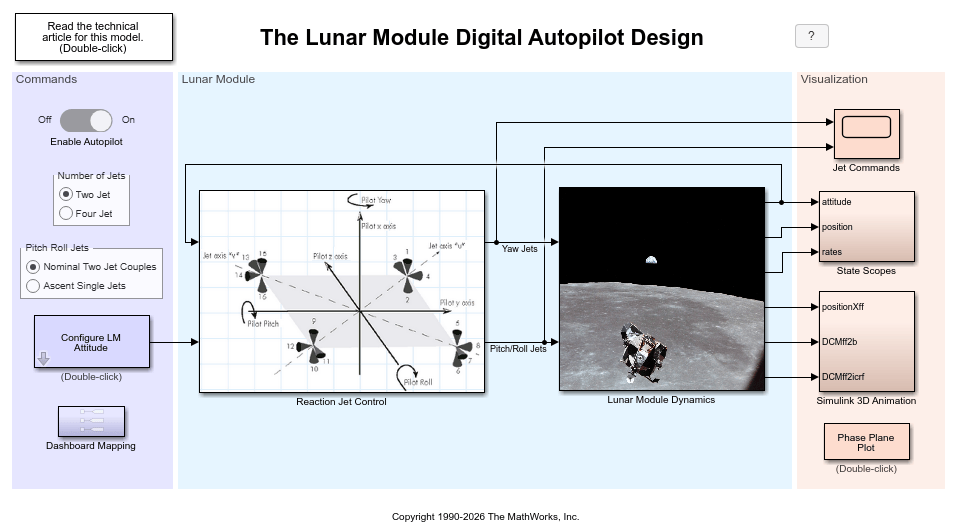
Developing the Apollo Lunar Module Digital Autopilot
Develop Apollo Lunar Module digital autopilot using Simulink® and Aerospace Blockset.
Ports
Input
Output
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"aerolibutil/Quaternion Rotation"
Example: add_block("aerolibutil/Quaternion Rotation","myModel/myBlock",MakeNameUnique="on")
Algorithms
The normalized quaternion has the form of
The vector has the form of
The Aerospace Blockset defines a passive quaternion rotation of the form:
where Ⓧ is the operator of a quaternion multiplication.
The final vector has the form of
References
[1] Stevens, Brian L., Frank L. Lewis. Aircraft Control and Simulation, Second Edition. Hoboken, NJ: Wiley–Interscience.
[2] Diebel, James. "Representing Attitude: Euler Angles, Unit Quaternions, and Rotation Vectors." Stanford University, Stanford, California, 2006.
Extended Capabilities
Version History
Introduced before R2006a

